|
I am a Ph.D. student at Peking University, advised by Prof. Hao Dong. Before this, I earned my Bachelor's degree from the Harbin Institute of Technology. My current research is centered on humanoid robot learning, with a specific focus on loco-manipulation and humanoid-object interaction. I am dedicated to developing general, generalizable, and scalable learning methods, aiming to empower humanoid robots to execute a wide variety of real-world tasks with human-like capability. |
|
News
|
|
|
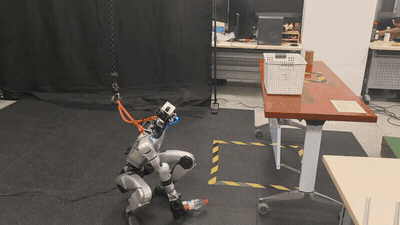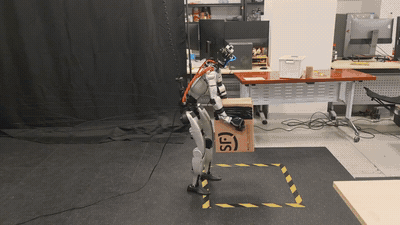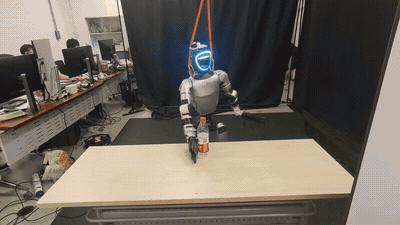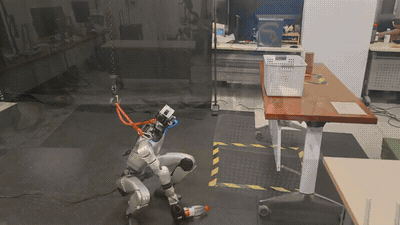
Tianshu Wu, Tianxiang Gui, Yue Chen, Tingxu Liu, Ziye Peng, Guangjie Yang, Xiangqi Kong, Ye Shi, Jingya Wang, Hao Dong arXiv, 2026 paper / project We present SUGARv2, a unified framework that synthesizes diverse interaction references and learns visual humanoid loco-manipulation skills through a shared training pipeline, enabling sim-to-real transfer across five tasks. |
|
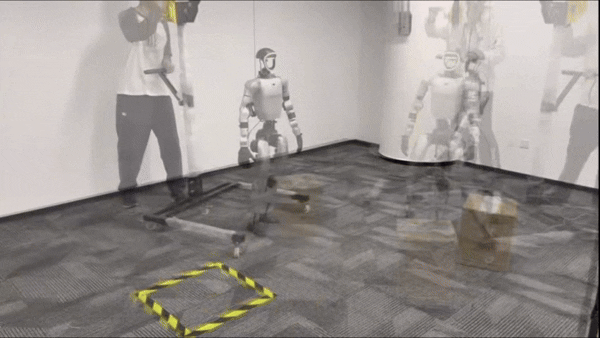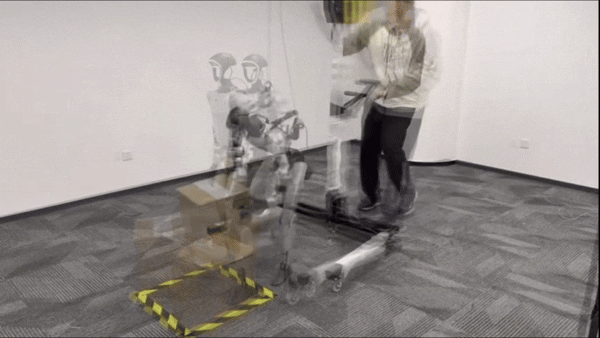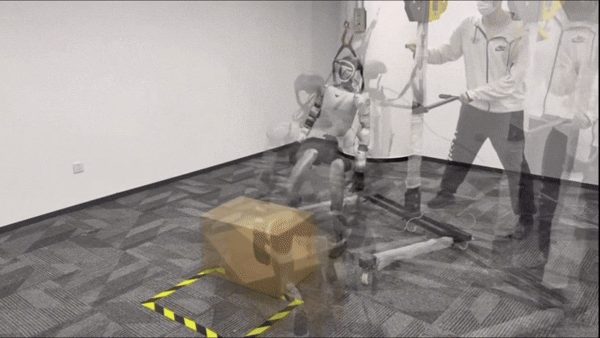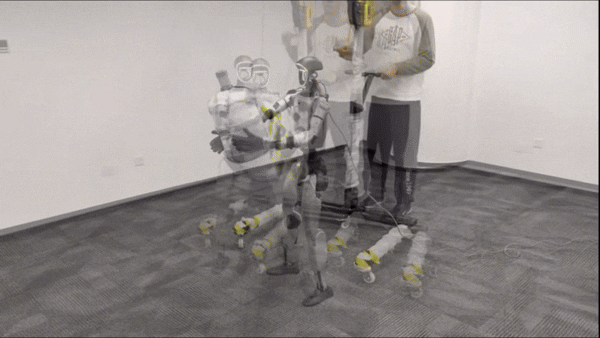
Tianshu Wu*, Xiangqi Kong*, Yue Chen*, Qize Yu, Hang Ye, Jia Li, Yizhou Wang, Hao Dong Advances in Neural Information Processing Systems (NeurIPS), 2026 paper / code / project We present SUGAR, a data-driven framework that converts diverse human videos into deployable humanoid loco-manipulation skills in a scalable and generalizable manner. |
|
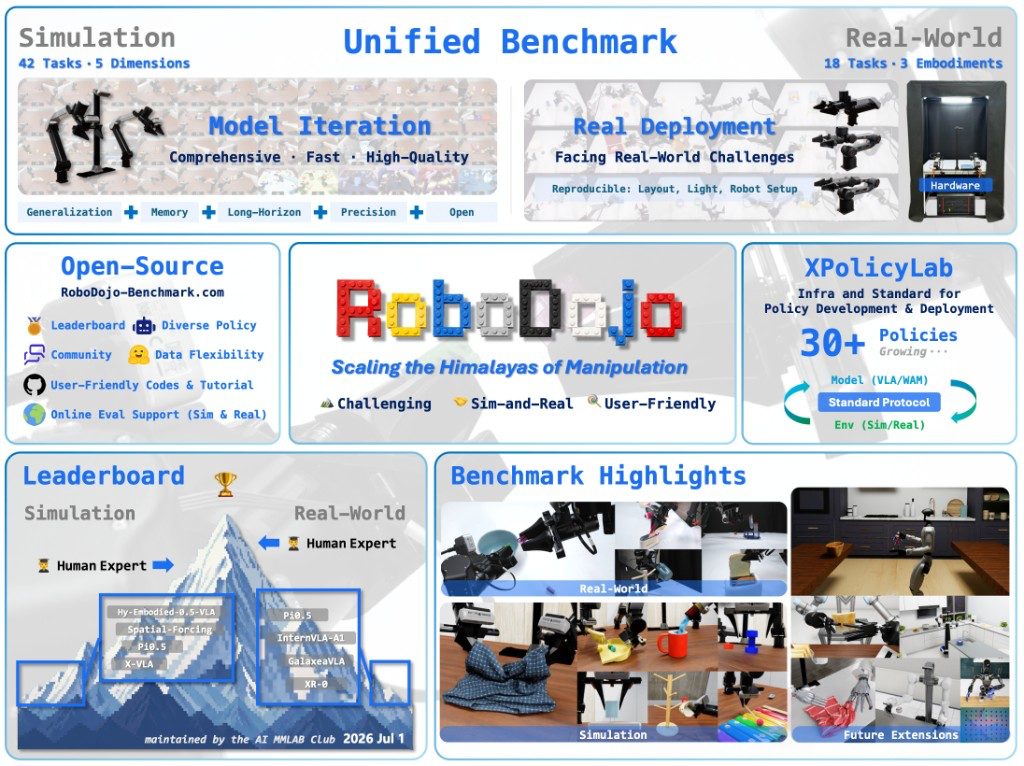
Arxiv, 2026 paper / code / project We present RoboDojo, a unified sim-and-real benchmark with 42 simulation tasks and 18 real-world tasks for comprehensive evaluation of generalist robot manipulation policies. |
|
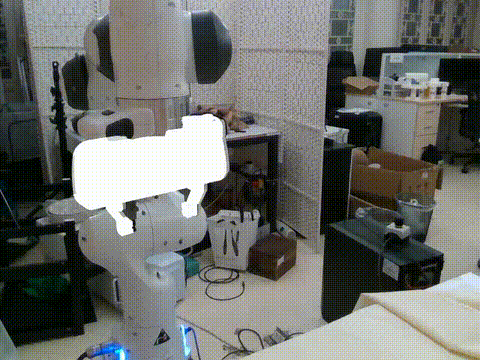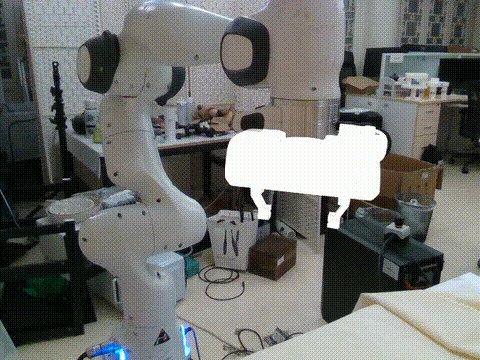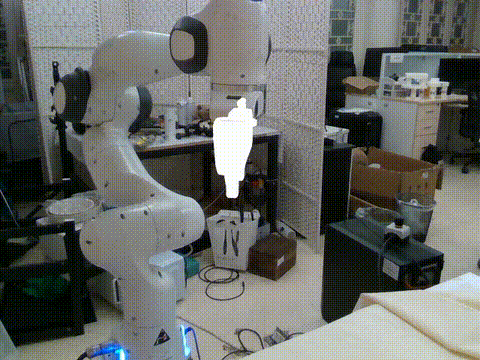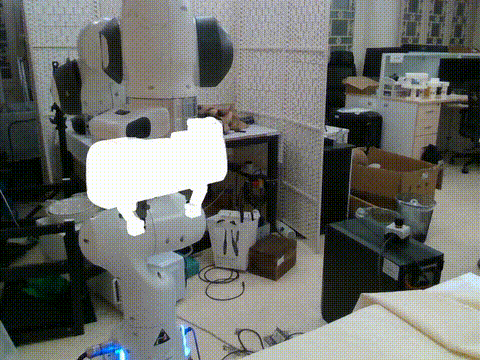
Tianshu Wu*, Jiyao Zhang*, Shiqian Liang*, Zhengxiao Han, Hao Dong International Conference on Robotics and Automation (ICRA), 2025 paper / code / project FEEPE uses foundation features for accurate, real-time end-effector pose estimation without markers or task-specific training. |
|
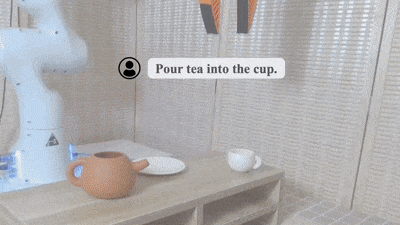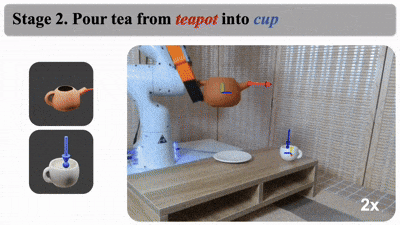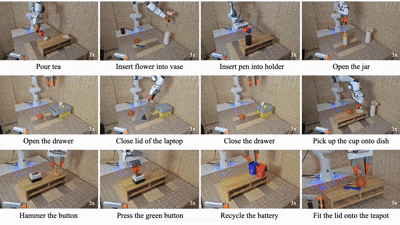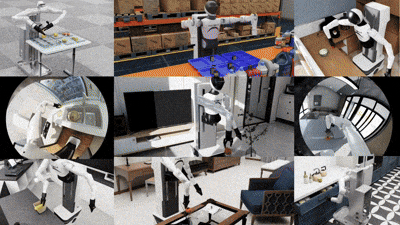
Mingjie Pan*, Jiyao Zhang*, Tianshu Wu, Yinghao Zhao, Wenlong Gao, Hao Dong Conference on Computer Vision and Pattern Recognition (CVPR), 2025, Highlight paper / project OmniManip combines VLM-guided planning with object-centric 3D constraints and 6D pose tracking for generalizable robotic manipulation without task-specific training. |
|
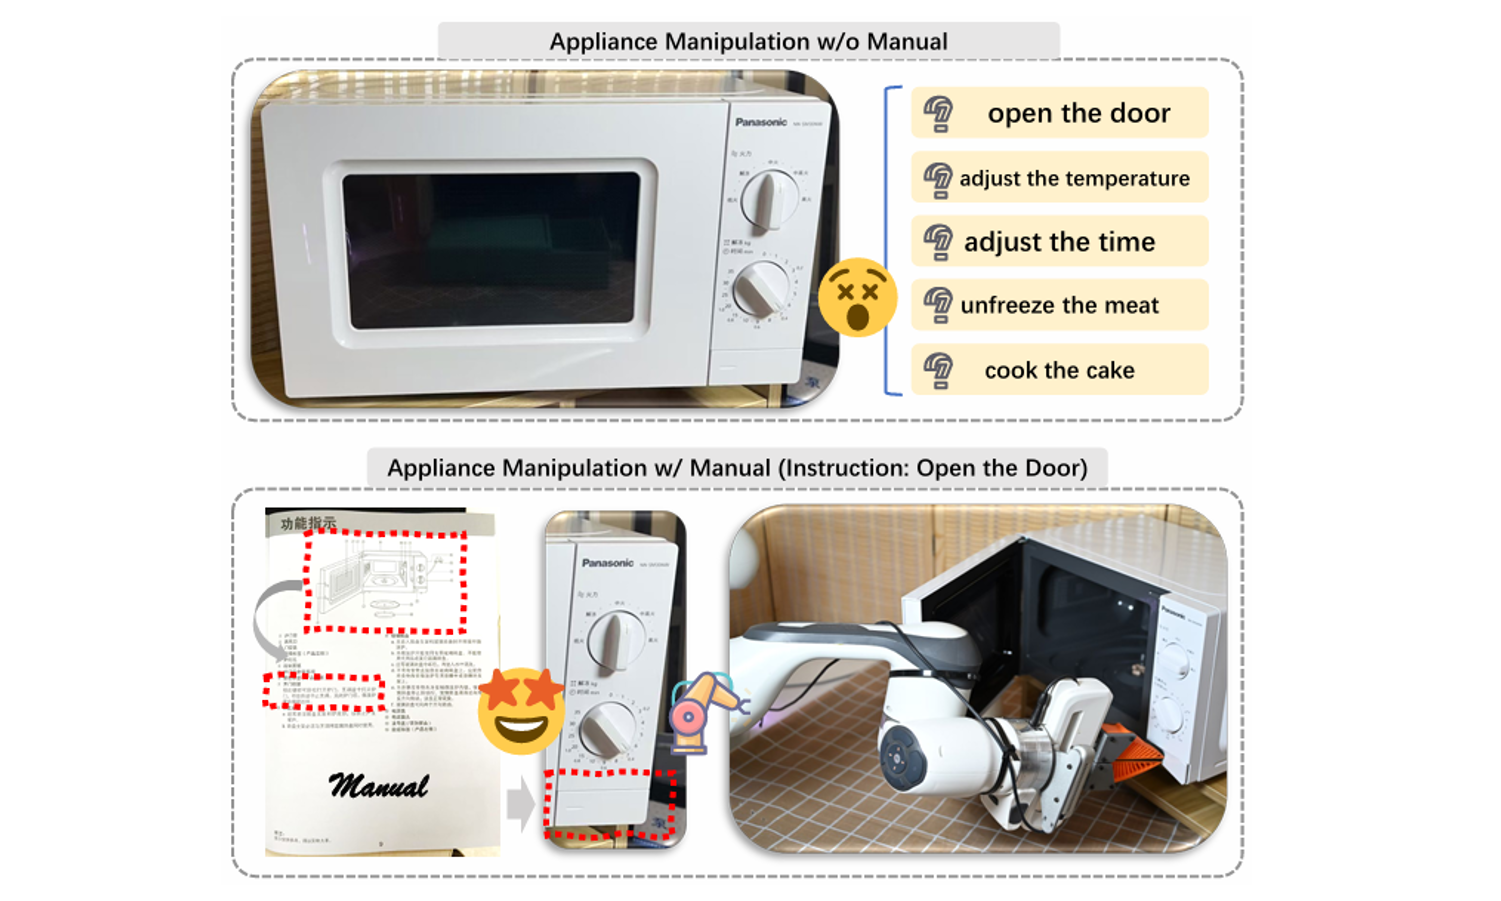
Yuxing Long, Jiyao Zhang, Mingjie Pan, Tianshu Wu, Taewhan Kim, Hao Dong Conference on Computer Vision and Pattern Recognition (CVPR), 2025, Highlight paper / code / project The first benchmark for manual-based appliance manipulation. |